Preprint · Computational geometry
Preprint — Polyline-Defined NC Trajectory Parametrisation
A compact method for approximating dense manufacturing paths with sequences of circular arcs and straight segments under a geometric tolerance.
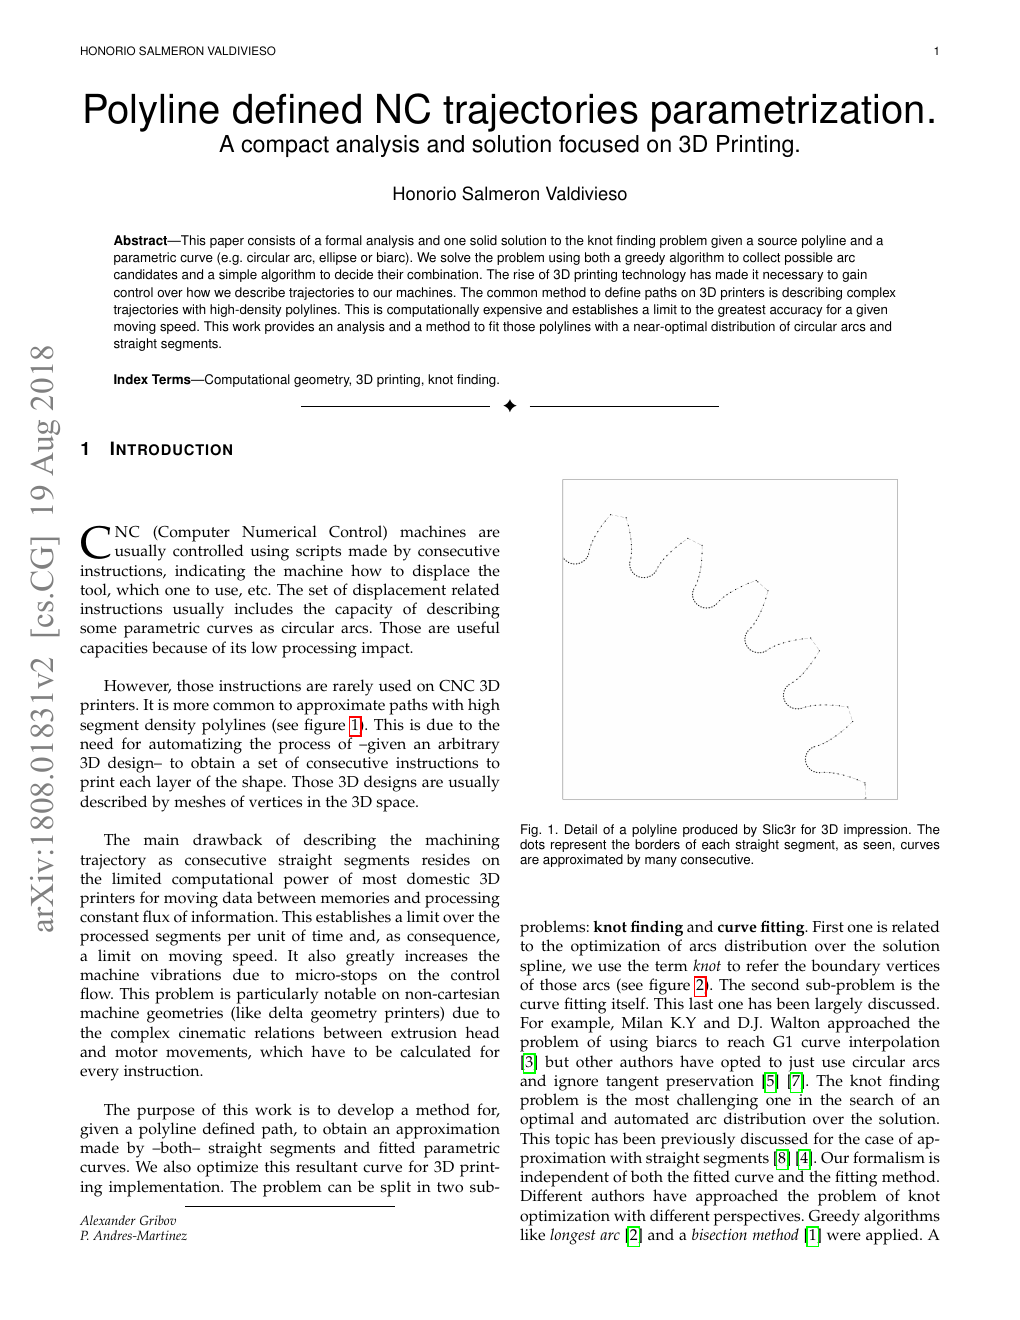
The work formalises candidate generation and selection for compact toolpath representation, motivated by the relationship between path density, machine communication, accuracy, and speed in digital fabrication.